Research on embodied foundation models, world models, embodied robot swarms, and aerial robotics. Preprints are labeled separately from peer-reviewed work. See also Google Scholar.
* co-first author with equal contribution; # Corresponding author.
22 publications
2026
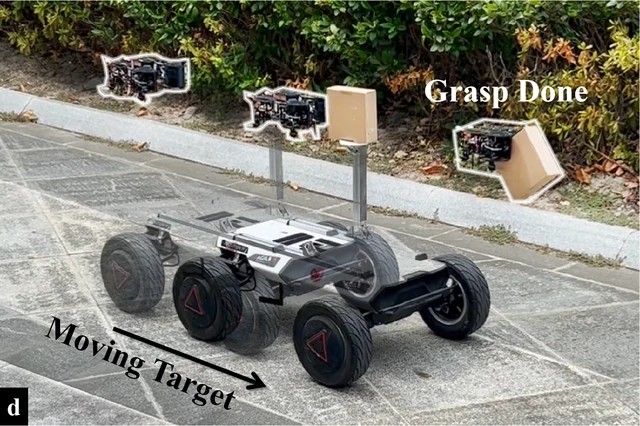
A Fully Onboard Integrated Aerial Grasping System for Moving Targets in Cluttered Environments
@article{diffwam-2026,
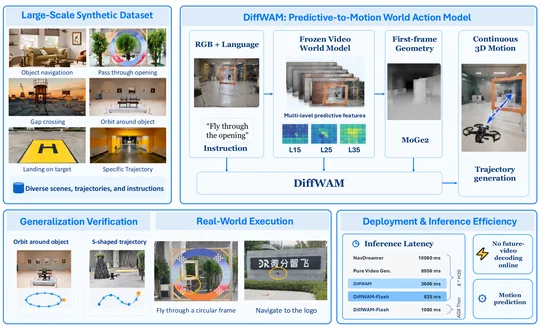
  title = {{DiffWAM: A Fast and Efficient Navigation World Action Model}},
  author = {Mo Zhu and Yuze Wu and Xijie Huang and Xiao Cui and Fei Gao and Xin Zhou},
  year = {2026},
  journal = {arXiv},
  eprint = {2609.39763},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2609.39763}
}
@article{navgen-2026,
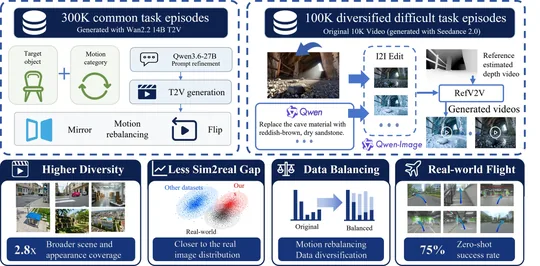
  title = {{NavGen: Visual Generative Models as a Scalable Data Engine for Embodied 3D Navigation}},
  author = {Xijie Huang and Yongyang Wan and Chengbin Dong and Zimo Ding and Mo Zhu and Yijin Wang and Zhiyang Liu and Fei Gao and Yuze Wu and Xin Zhou},
  year = {2026},
  journal = {arXiv},
  eprint = {2609.30770},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2609.30770}
}
@article{flymirage-2026,
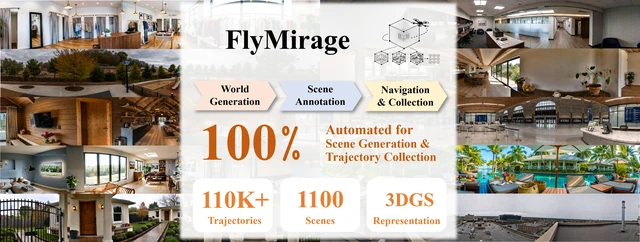
  title = {{FlyMirage: A Fully Automated Generation Pipeline for Diverse and Scalable UAV Flight Data via Generative World Model}},
  author = {Jinhan Li and Xijie Huang and Weiqi Gai and Zhaoqi Wang and Qiyi He and Yijin Wang and Mo Zhu and Zhiyang Liu and Fei Gao and Xin Zhou and Yuze Wu and Ziming Ding},
  year = {2026},
  journal = {arXiv},
  eprint = {2605.19600},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2605.19600}
}
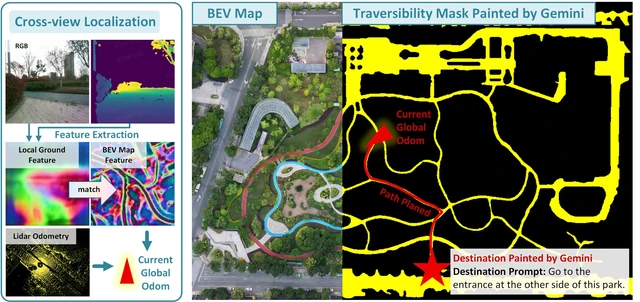
@inproceedings{pathpainter-2026,
  title = {{PathPainter: Transferring the Generalization Ability of Image Generation Models to Embodied Navigation}},
  author = {Yijin Wang and Yuru Tian and Xijie Huang and Weiqi Gai and Mo Zhu and Xin Zhou and Yuze Wu and Fei Gao},
  year = {2026},
  booktitle = {CoRL},
  eprint = {2605.07496},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2605.07496}
}
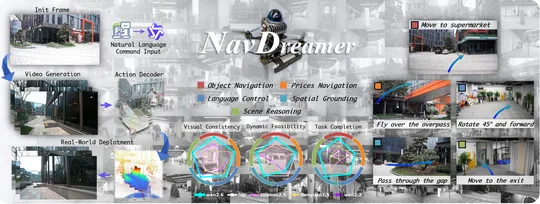
@article{navdreamer-2026,
  title = {{NavDreamer: Video Models as Zero-Shot 3D Navigators}},
  author = {Xijie Huang and Weiqi Gai and Tianyue Wu and Congyu Wang and Zhiyang Liu and Xin Zhou and Yuze Wu and Fei Gao},
  year = {2026},
  journal = {IEEE Robotics and Automation Letters},
  eprint = {2602.09765},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2602.09765}
}
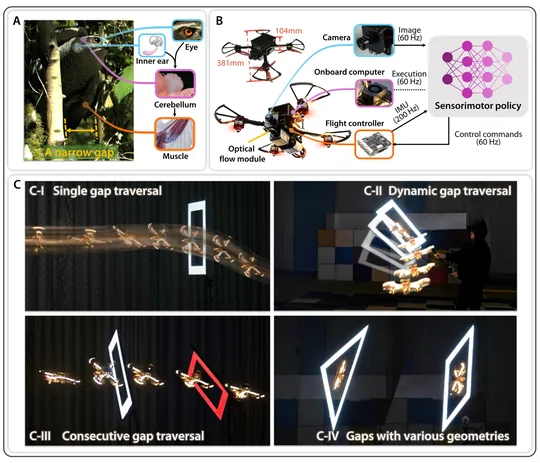
@article{sensorimotor-2026,
  title = {{Precise aggressive aerial maneuvers with sensorimotor policies}},
  author = {Tianyue Wu and Guangtong Xu and Zihan Wang and Junxiao Lin and Tianyang Chen and Yuze Wu and Zhichao Han and Zhiyang Liu and Fei Gao},
  year = {2026},
  journal = {Science Robotics},
  doi = {10.1126/scirobotics.aeb0180},
  eprint = {2604.05828},
  archivePrefix = {arXiv},
  url = {https://doi.org/10.1126/scirobotics.aeb0180}
}
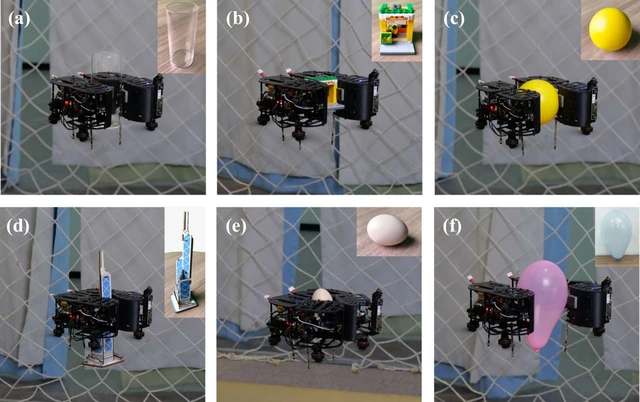
@article{hiarm-2026,
  title = {{Hand-like autonomous flying robot for airborne grasping and interaction}},
  author = {Yuze Wu and Fan Yang and Rui Jin and Yuhang Zhong and Junjie Wang and Xuankang Wu and Fei Gao},
  year = {2026},
  journal = {Nature Communications},
  doi = {10.1038/s41467-026-68967-3},
  volume = {17},
  url = {https://www.nature.com/articles/s41467-026-68967-3}
}
@inproceedings{force-grasp-2026,
  title = {{A Precise Real-Time Force-Aware Grasping System for Robust Aerial Manipulation}},
  author = {Kenghou Hoi and Yuze Wu and Annan Ding and Junjie Wang and Anke Zhao and Jialiang Hou and Chengqian Zhang and Fei Gao},
  year = {2026},
  booktitle = {ICRA},
  eprint = {2602.08599},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2602.08599}
}
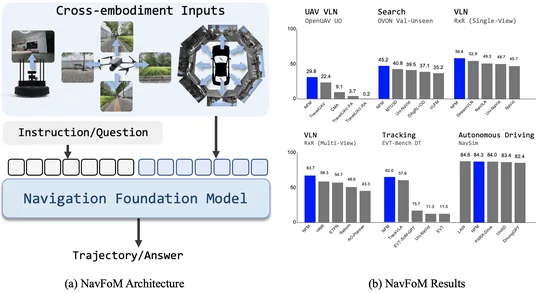
@inproceedings{navfom-2026,
  title = {{Embodied Navigation Foundation Model}},
  author = {Jiazhao Zhang and Anqi Li and Yunpeng Qi and Minghan Li and Jiahang Liu and Shaoan Wang and Haoran Liu and Gengze Zhou and Yuze Wu and Xingxing Li and Yuxin Fan and Wenjun Li and Zhibo Chen and Fei Gao and Qi Wu and Zhizheng Zhang and He Wang},
  year = {2026},
  booktitle = {ICLR},
  eprint = {2509.12129},
  archivePrefix = {arXiv},
  url = {https://openreview.net/forum?id=kkBOIsrCXh}
}
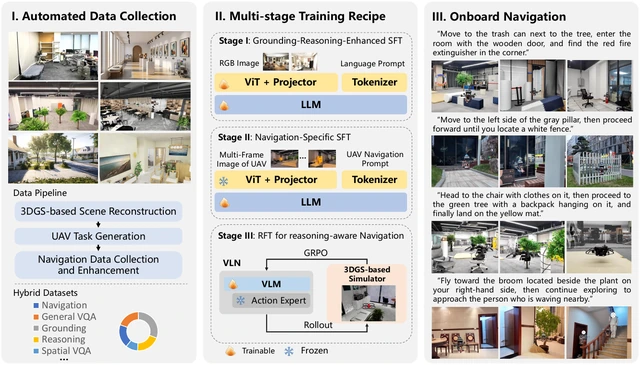
@article{vln-ar-2026,
  title = {{A Hierarchical Onboard Vision-Language-Navigation Framework for Aerial Robots in Complex Environments}},
  author = {Yuze Wu and Mo Zhu and Xingxing Li and Yuheng Du and Zhaoqi Wang and Yuxin Fan and Wenjun Li and Kenghou Hoi and Zhichao Han and Xin Zhou and Fei Gao},
  year = {2026},
  journal = {IEEE Transactions on Robotics},
  doi = {10.1109/TRO.2026.3754505},
  pages = {1--20},
  eprint = {2611.23930},
  archivePrefix = {arXiv},
  url = {https://ieeexplore.ieee.org/document/11803153}
}
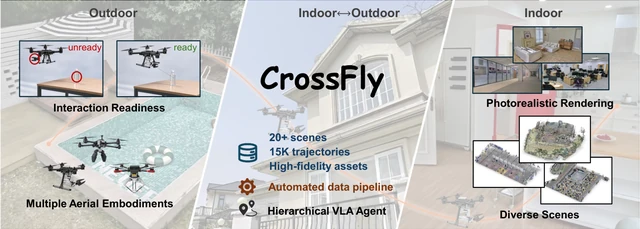
@article{crossfly-2026,
  title = {{Benchmarking Interaction-Oriented Aerial Mobility across Heterogeneous Environments}},
  author = {Zhibo Duan and Hanlin Kong and Tianran Ma and Yuze Wu and Yuxuan Xu and Kenghou Hoi and Changheng Xie and Xin Zhou and Jianzhe Gao and Fei Gao and Wenguan Wang},
  year = {2026},
  journal = {arXiv},
  eprint = {2610.18381},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2610.18381}
}
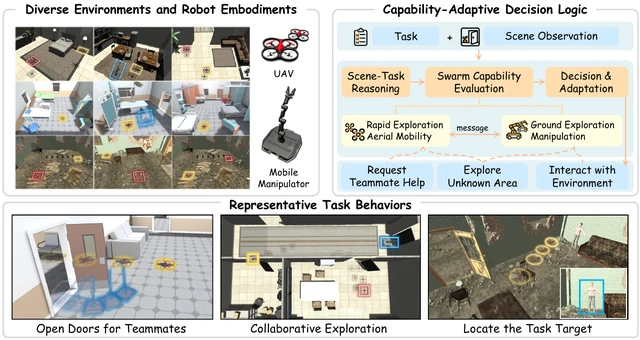
@article{d-vlc-2026,
  title = {{D-VLC: Decentralized Vision-Language Collaboration for Heterogeneous Embodied Multi-Robot Systems in Unknown Environments}},
  author = {Yuan Zhou and Ruitong Lin and Shen Wang and Weiqi Gai and Mo Zhu and Xin Zhou and Yuze Wu and Fei Gao},
  year = {2026},
  journal = {arXiv},
  eprint = {2607.29009},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2607.29009}
}
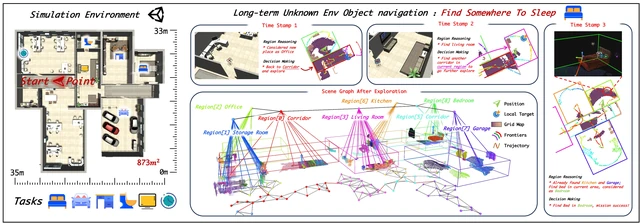
@article{uss-nav-2026,
  title = {{USS-Nav: Unified Spatio-Semantic Scene Graph for Lightweight UAV Zero-Shot Object Navigation}},
  author = {Weiqi Gai and Yuman Gao and Yuan Zhou and Yufan Xie and Zhiyang Liu and Yuze Wu and Xin Zhou and Fei Gao and Zhijun Meng},
  year = {2026},
  journal = {arXiv},
  eprint = {2602.00708},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2602.00708}
}
@article{reactive-aerobatic-2025,
  title = {{Reactive Aerobatic Flight via Reinforcement Learning}},
  author = {Zhichao Han and Xijie Huang and Zhuxiu Xu and Jiarui Zhang and Yuze Wu and Mingyang Wang and Tianyue Wu and Fei Gao},
  year = {2025},
  journal = {IEEE Robotics and Automation Letters},
  doi = {10.1109/LRA.2025.3606383},
  volume = {10},
  number = {10},
  pages = {11014–11021},
  eprint = {2505.24396},
  archivePrefix = {arXiv},
  url = {https://ieeexplore.ieee.org/document/11151206}
}
@inproceedings{shape-adaptive-2025,
  title = {{Shape-Adaptive Planning and Control for a Deformable Quadrotor}},
  author = {Yuze Wu and Zhichao Han and Xuankang Wu and Yuan Zhou and Junjie Wang and Zheng Fang and Fei Gao},
  year = {2025},
  booktitle = {IROS},
  doi = {10.1109/IROS60139.2025.11245898},
  url = {https://arxiv.org/abs/2505.15010}
}
@inproceedings{float-2025,
  title = {{FLOAT Drone: A Fully-actuated Coaxial Aerial Robot for Close-Proximity Operations}},
  author = {Junxiao Lin and Shuhang Ji and Yuze Wu and Tianyue Wu and Zhichao Han and Fei Gao},
  year = {2025},
  booktitle = {IROS},
  doi = {10.1109/IROS60139.2025.11245967},
  url = {https://arxiv.org/abs/2503.00785}
}
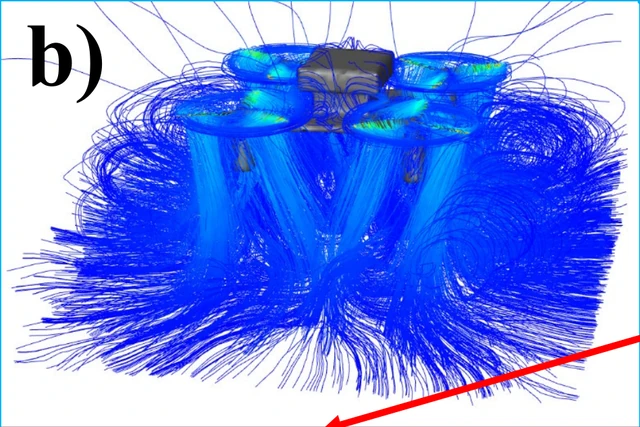
@article{ground-effect-2025,
  title = {{Ground-Effect-Aware Modeling and Control for Multicopters}},
  author = {Tiankai Yang and Kaixin Chai and Jialin Ji and Yuze Wu and Chao Xu and Fei Gao},
  year = {2025},
  journal = {arXiv},
  eprint = {2506.19424},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2506.19424}
}
@article{ring-rotor-2023,
  title = {{Ring-Rotor: A Novel Retractable Ring-Shaped Quadrotor With Aerial Grasping and Transportation Capability}},
  author = {Yuze Wu and Fan Yang and Ze Wang and Kaiwei Wang and Yanjun Cao and Chao Xu and Fei Gao},
  year = {2023},
  journal = {IEEE Robotics and Automation Letters},
  url = {https://ieeexplore.ieee.org/document/10044964}
}
@inproceedings{model-based-tabv-2023,
  title = {{Model-Based Planning and Control for Terrestrial-Aerial Bimodal Vehicles with Passive Wheels}},
  author = {Ruibin Zhang and Junxiao Lin and Yuze Wu and Yuman Gao and Chi Wang and Chao Xu and Yanjun Cao and Fei Gao},
  year = {2023},
  booktitle = {IROS},
  url = {https://ieeexplore.ieee.org/document/10342188}
}
@inproceedings{roller-quadrotor-2023,
  title = {{Roller-Quadrotor: A Novel Hybrid Terrestrial-/Aerial Quadrotor with Unicycle-Driven and Rotor-Assisted Turning}},
  author = {Zhi Zheng and Jin Wang and Yuze Wu and Qifeng Cai and Huan Yu and Ruibin Zhang and Jie Tu and Jun Meng and Guodong Lu and Fei Gao},
  year = {2023},
  booktitle = {IROS},
  url = {https://ieeexplore.ieee.org/document/10341703}
}
@article{adaptive-tabv-2022,
  title = {{Autonomous and Adaptive Navigation for Terrestrial-Aerial Bimodal Vehicles}},
  author = {Ruibin Zhang and Yuze Wu and Lixian Zhang and Chao Xu and Fei Gao},
  year = {2022},
  journal = {IEEE Robotics and Automation Letters},
  doi = {10.1109/LRA.2022.3145505},
  url = {https://ieeexplore.ieee.org/document/9691888}
}
No publications match this search. Try another title, author or year.